The mathematics of
preserving structure.
Research settingNASAFoundational origins
Much of this program’s foundational mathematics and manifold work developed under NASA; the collection also includes later developments.
The way we represent data changes what our calculations can tell us. My research asks how to preserve the relationships that make those calculations meaningful.
The idea in 30 seconds.
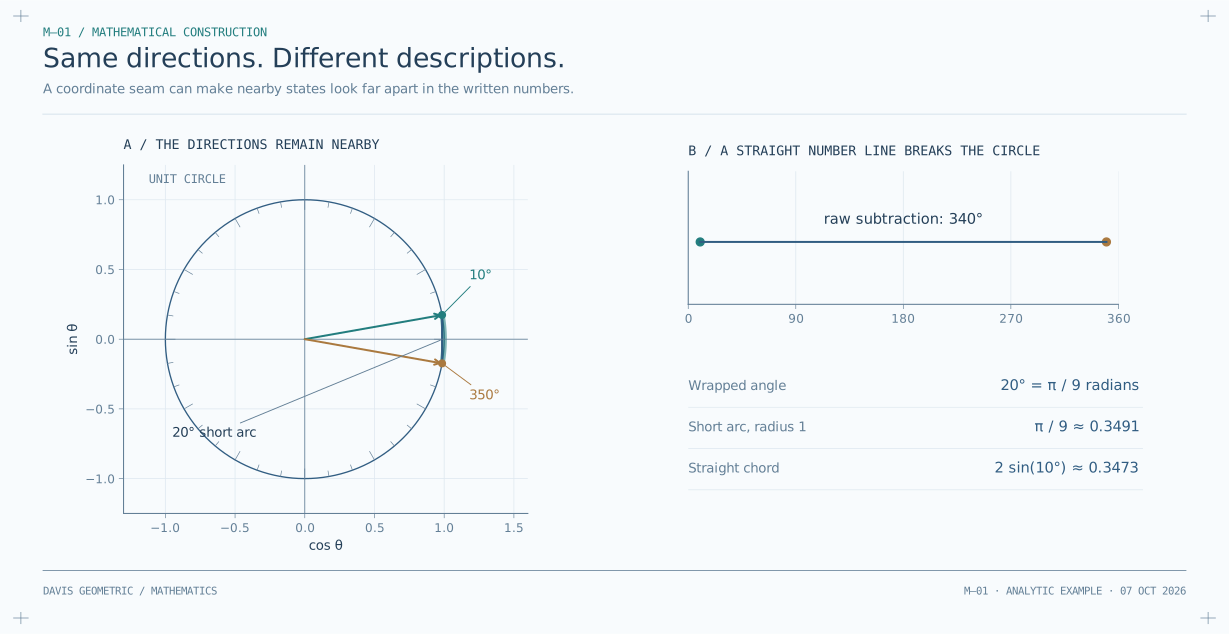
A compass reading of 350° is only 20° from 10°, even though subtracting the numbers gives 340°. The arithmetic is correct, but it misses the fact that directions wrap around. A calculation can be right while its representation gives us the wrong picture.
That is the common thread across this work. I study what different descriptions treat as the same, how they measure change, and what gets lost when we translate or simplify them. Geometry provides tools for expressing those relationships. The aim is to carry them through the computation and establish useful bounds on the error. Each topic below explores part of that question, with its own assumptions and evidence.
A classic idea, read geometrically
More path than precision.
Put five letters into four mailboxes: at least two share a box. Now replace letters with readings along a path, and mailboxes with small neighborhoods in a space of states. Enough separated readings force a near-repeat.
L is the total interval; T is the spacing you choose. N small balls cover the state space. Sample at 0, T, 2T, …, NT.
Assign each reading to the first ball containing it. There are more readings than balls, so two share a ball.
Call the two sample times s and t. Distinct points on the sampling grid are at least T apart.
H(t) means the state read at time t. Each shared-ball reading is at most ε from the center, so the distance between them is at most ε + ε.
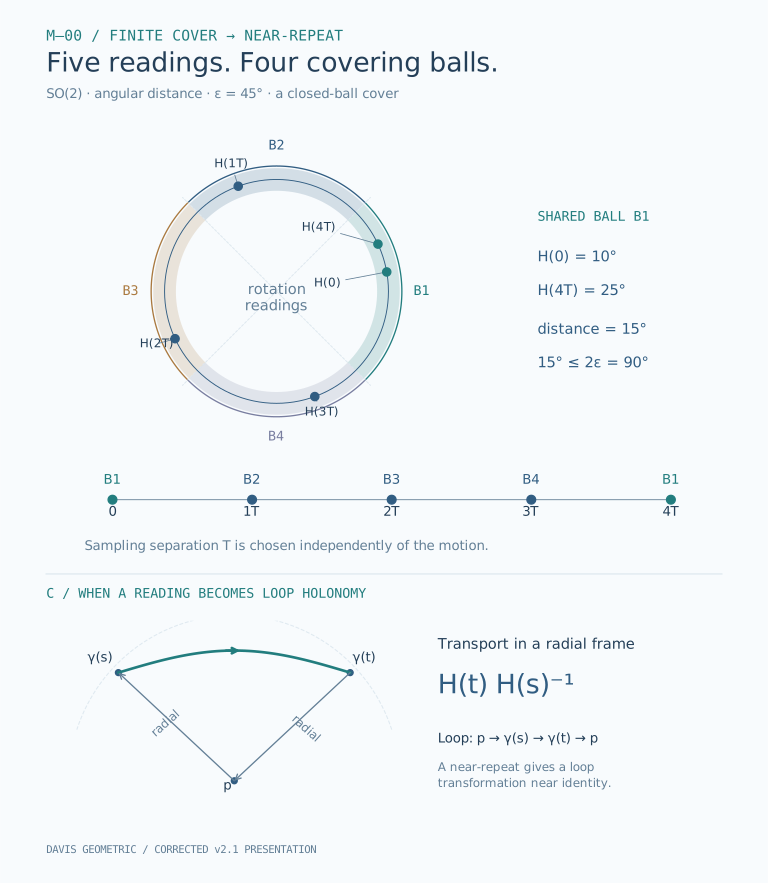
What this proves: a separated near-repeat of two readings, which need not include the initial reading. A constant reading also qualifies. A genuine excursion-and-return needs the additional condition below.
Read the complete proof and its holonomy interpretation
Theorem A · finite-cover pigeonhole
Let (X, d) be a metric space, ε > 0, and N = NX(ε) < ∞ its ε-covering number. Fix an ordered cover by N radius-ε balls. Let H: [0, L] → X be any map, and prescribe T > 0. No continuity is required.
Proof. The N+1 times tj = jT, j = 0, …, N, all lie in [0, L]. Assign each reading to the first ball containing it. Two readings share a ball. Their distances to its center sum to at most 2ε, while their distinct sampling times differ by at least T. This is the classical pigeonhole principle applied to a finite cover. L* = NT is a sufficient horizon, not a claim about the earliest repeat.
Why a near-repeat is not yet a return
A constant map never leaves home, yet satisfies Theorem A. Under the same setup, Theorem B adds R > 2ε and τ > 0, with an excursion from every starting time: for each s ∈ [0, L−τ], some u ∈ [s, s+τ] satisfies d(H(u), H(s)) > R. If L ≥ Nτ, there exist s < u < t with d(H(s), H(t)) ≤ 2ε and d(H(u), H(s)) > R.
Proof. Apply Theorem A with T = τ and order its two times s < t. The promised excursion fits into [s, s+τ] ⊆ [s, t]. Its distance exceeds R > 2ε, so u is neither s nor t. This supplies the intervening excursion.
Where parallel transport enters
Along a smooth unit-speed path γ on a Riemannian manifold, fix a smooth orthonormal reference frame F(t). Read the parallel-transported initial frame in F(t): H(t) = [Pγ|[0,t]F(0)]F(t). These readings lie in SO(n). Give that group a fixed normalized bi-invariant metric. Its compactness supplies a finite covering number.
H(t) is transport expressed in a frame, rather than itself a closed-loop holonomy. With a radial frame from p, the loop p → γ(s) → γ(t) → p has matrix H(t)H(s)−1 in the frame at p. Bi-invariance gives d(H(s), H(t)) = d(I, H(t)H(s)−1). A near-repeat thus gives a loop holonomy close to the identity. An arbitrary moving frame does not provide that geometric closing path.
What curvature does—and what it does not supply
The connection form ω in F gives H′ = −ω(γ′)H and the Lipschitz bound d(H(s), H(t)) ≤ Λ|s−t|, with Λ = sup ‖ω(γ′)‖. For 0 < Λ < ∞ and T ≤ L, the pair (0, T) already gives a near-repeat whenever T ≤ 2ε/Λ. Above that threshold, this estimate alone no longer suffices. If Λ = 0, the reading is constant.
The source’s radial-frame estimate Λ ≤ C(n)κr₀ is stated under all of these conditions: |K| ≤ κ, γ ⊂ B(p, r₀), r₀ < inj(p), and √κ r₀ ≤ c for a fixed sufficiently small c > 0. See the small-ball definitions. This bounds the rate; it does not force an excursion, determine the earliest return, or establish a horizon proportional to 1/κ. The elementary animation uses Theorem A and does not depend on this geometric estimate.
Source: the supplied v2.1 text, recovered from its untruncated readout in the linked review chat, with the subsequent board corrections incorporated into this presentation. The source snapshot retains its original “v2” heading. Theorem A is a standard finite-cover application of pigeonhole, not a claim of a new counting principle.
Definitions for the board Pigeonhole principle · ε-ball / covering number · Holonomy · Reference frame / radial frame
Six ways into the research.
Basic algebra, angles and fractions are enough to start. Each entry begins with an example, walks through the calculation, and then connects it to the research question. Open the formal notes when you are ready for the next level.
This is a conceptual reading order, not a chain of six proved dependencies.
From the early manifold framework to The Geometry of Sameness
Representation & sameness
When do translations and distances describe the same thing?
Start here / a worked example
You already know that 350° and 10° are close.
Start with a compass.
Two directions lie on either side of north: 350° and 10°. Subtracting the written numbers gives 340°. But the short turn from one direction to the other is only 20°.
Change the description; keep the direction.
Put each direction on a unit circle using (cos θ, sin θ). Both points now sit near (1, 0). Their straight-line separation is about 0.347, while the short arc is about 0.349. Those are different measurements, but both retain the fact that the directions are close.
Ask what a translation must preserve.
A representation should carry the relationships needed by the calculation. In this example that means respecting the wrap around at 360°. The research extends this question to translators between data formats and manifolds: under which assumptions do the two descriptions preserve identity, distance and decisions?
The circle is a concrete starting example. It does not prove that every dataset admits the required geometry.
Words for this step Equivalence · Metric · Distortion
Go deeper · precise statements, proofs & research scope
Conditional framework · explicit proof obligations
New terminology is linked to the definitions.
The starting point is a shared notion of identity. One system represents it through translators between observation formats; another uses distances and paths on a manifold. The research asks when these are compatible descriptions, and which error guarantees can pass between them.
The Geometry of Sameness develops this through categories of realizations and a proposed approximate equivalence. Smooth chartability, Riemannian realizability, controlled distortion and aligned detectors are essential hypotheses.
A precise result: transferring component error budgets
For four component error parameters ei in [0,1], define B(e) = 1 − ∏i(1 − ei). Then
Replace the four factors one at a time. Each term in the telescoping difference is a component difference times factors bounded by one. The triangle inequality gives the result. If independence-slack terms δ differ, add |δe − δf|.
This proves stability of the budget expression once its inputs are controlled. Interpreting that expression as an actual failure probability requires independence or a justified dependence correction. It does not construct a manifold or establish detector alignment.
Scope & review. The population Cantelli step and the budget algebra have focused checks. The larger equivalence and training-to-distortion claims are not certified here; metric compatibility alone does not control chordal distortion, and threshold stability needs additional distributional assumptions. Review notes →
Double Cover Principle · the line of work developed into SUPERFLUID
Double covers & observables
What is lost when two descriptions become one?
Start here / a worked example
An arrow and a line do not distinguish the same things.
Turn an arrow halfway around.
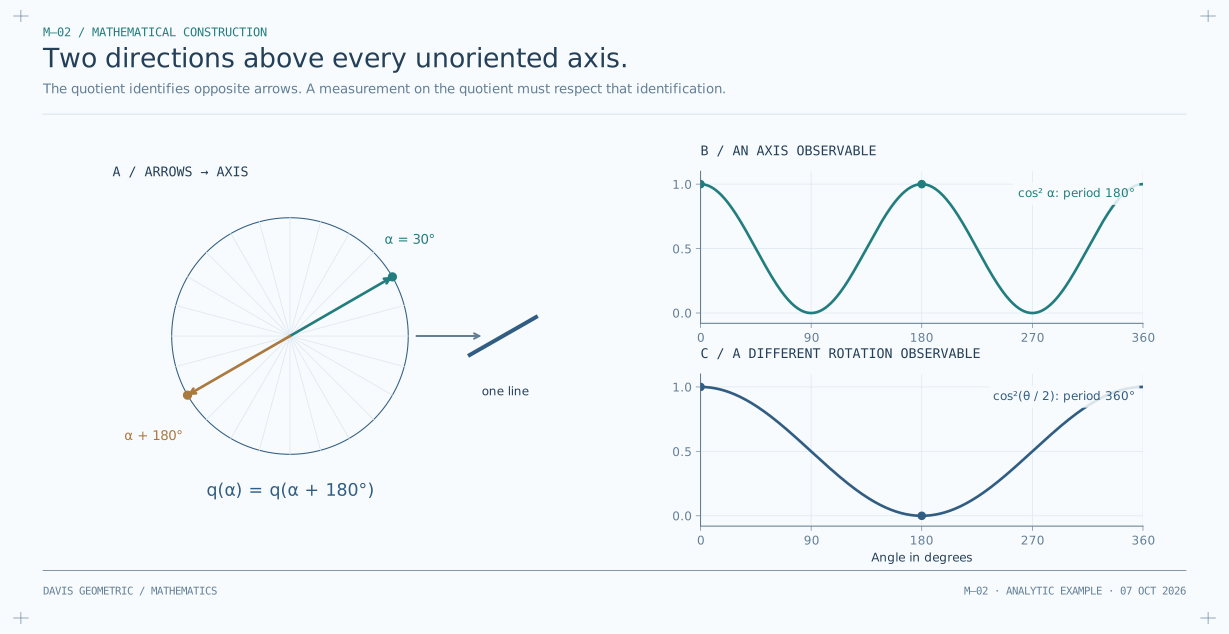
An arrow pointing northeast becomes an arrow pointing southwest after a 180° turn. They point in different directions. A full 360° turn restores the original arrow.
Now erase the arrowhead.
The northeast–southwest line is unchanged by that same 180° turn. Each unoriented line corresponds to two opposite arrows. Sending an arrow to its line is a double cover.
Check what a measurement can tell apart.
If your measurement is supposed to depend only on the line, opposite arrows must give the same answer. A measurement that changes when the arrow reverses needs the extra directional information.
The paper also studies half-angle overlaps. For θ = 60°, cos²(θ/2) = 3/4 and sin²(θ/2) = 1/4. They add to one. This trigonometric identity is exact, but the overlap is not automatically an observable on the arrow-to-line quotient.
Words for this step Quotient · Double cover · Observable · S¹, ℝP¹ and eⁱᵅ
Go deeper · precise statements, proofs & research scope
Exact identities · coordinate and model restrictions
New terminology is linked to the definitions.
A directed arrow and an unoriented axis distinguish different states. Forgetting the arrowhead gives the standard two-to-one cover S¹ → ℝP¹: opposite arrows describe one axis. With the metric inherited from the unit circle, the quotient has circumference π.
The manuscript also studies a rotation observable S(θ) = cos²(θ/2) and chord magnitude K = |1 − eiθ|. Keeping the rotation angle θ distinct from the quotient coordinate α makes the algebra and the interpretation easier to separate.
Proof and the finite-ring distinction
The identities follow from cos²u + sin²u = 1 and |1 − eiθ|² = 2 − 2 cos θ. For a highest-weight spin-j state rotated about a transverse axis, the squared overlap is cos4j(θ/2); the validation constructs the spin matrices independently.
For the stated aromatic-ring Hamiltonian, N = 4k + 2 and 0 ≤ θ ≤ π, the finite-size gap ratio is
Its limit is 1 − θ/π. Substituting θ = 2 arcsin(K/2) gives the arcsine expression in that limit. Commutativity alone does not impose linear gap closure.
Scope & review. The half-angle overlap is not a function on the arrow-axis quotient with the same angle: θ = 0 and π identify one axis but give overlaps 1 and 0. The overlap, chord identity and cover are useful distinct constructions, not a universal two-class law. Review notes →
A precise reading of No Parallel Lines
Curvature & path dependence
When does the route between states matter?
Start here / a worked example
Return to the same place. Check the direction.
Begin with a flat sheet of paper.
Slide a small arrow around a triangle without rotating it. Back at the start, it points in its original direction. The location and direction have both returned.
Repeat on a sphere.
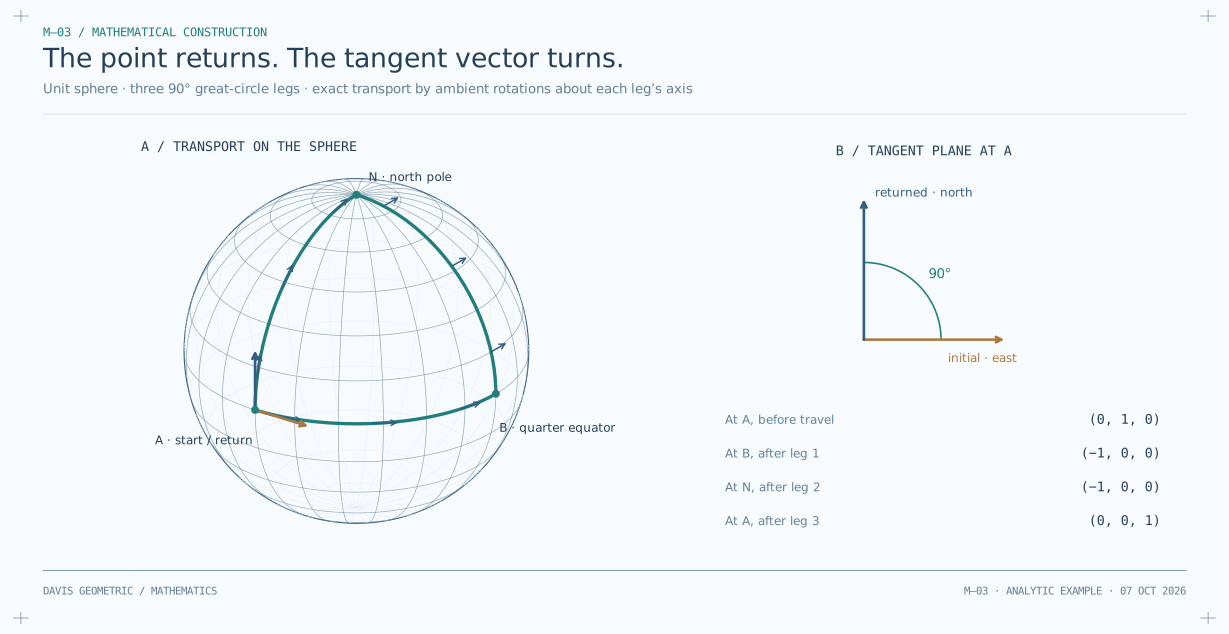
Use the unit sphere. Start on the equator, travel east through 90° of longitude, go north to the pole, and follow a meridian back to the start. Carry a tangent arrow using parallel transport: do not turn it within the surface’s local tangent plane.
For this particular loop, an initially east-pointing arrow comes back pointing north. The 90° change is holonomy. The blueprint tracks the vectors along each leg; this is a computed geometric example, not a compass-needle experiment.
Separate local geometry from global topology.
A connection specifies the transport rule. Its curvature describes the effect of small loops. On a space with holes, even a flat connection can retain a change around a large loop. That is why the formal statement needs a topological condition as well as zero curvature.
Words for this step Parallel transport · Holonomy · Connection · Simply connected / homotopy
Go deeper · precise statements, proofs & research scope
Classical connection theory · quantitative extension needs repair
New terminology is linked to the definitions.
A connection tells us how to compare states along a path. Its curvature measures infinitesimal path dependence. This supplies a precise mathematical language for asking what a model loses when it treats transport as globally independent of the route.
For a smooth principal-bundle connection over a connected, simply-connected base, flatness is equivalent to trivial holonomy and a global parallel trivialization. On a general base, flatness only removes the contribution from contractible loops; global holonomy can remain.
Why the topology matters
With zero curvature, parallel transport is unchanged under endpoint-fixed homotopy. On a simply-connected base, paths with the same endpoints are homotopic, so transport gives a consistent global parallel section. Conversely, a parallel trivialization has zero local gauge potential and therefore zero curvature.
On S¹, the flat U(1) connection A = ½ dθ has loop holonomy exp(iπ) = −1. It is a counterexample to dropping the simple-connectivity or trivial-holonomy condition.
See Hoskins, notes on flat connections, §4 for the standard connection-theoretic setting.
Scope & review. The qualitative statement is retained with its hypotheses. The manuscript’s universal energy-to-model-error inequality and failure-localization claim are not established by this review. “No Parallel Lines” is an original title, not a literal claim about every curved geometry. Review notes →
From the Approximation–Obstruction Duality manuscript
Approximation & obstruction
How much structure can a local linear model retain?
Start here / a worked example
How far does a straight line miss a parabola?
Join two values you can calculate.
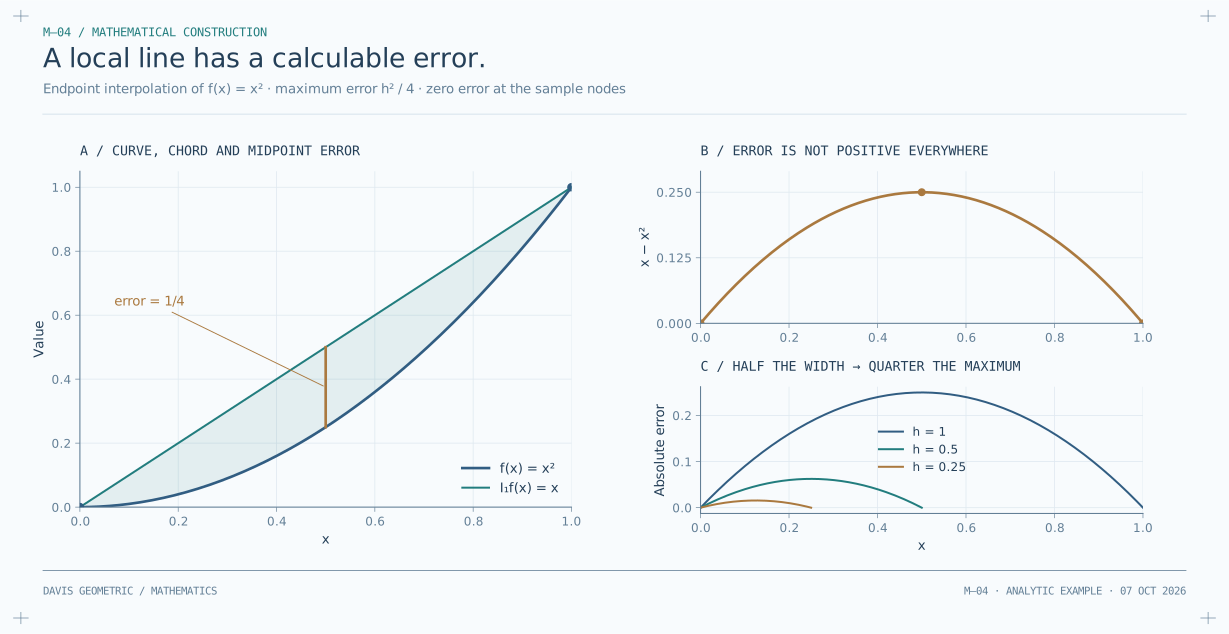
Take f(x) = x² between 0 and 1. Its endpoint values are 0 and 1. The straight line joining them is y = x: the linear interpolant.
Measure the miss halfway across.
At x = 1/2, the line gives 1/2 and the parabola gives 1/4. The error is 1/4. More generally, x − x² = 1/4 − (x − 1/2)², so 1/4 is the largest error on this interval. At both endpoints, the error is zero.
Make the interval smaller.
On [0, h], the joining line is hx and the maximum error is h²/4. Halving the interval divides this error by four. The second derivative of x² is 2, so this exactly meets the bound h² × 2/8.
The research asks which versions of this relationship survive for more complex models. “The worst error is at most this much” and “every point must have at least this much error” are very different claims.
Words for this step Derivative / Hessian · Linear interpolant · Supremum norm, ‖f‖∞ · Bound / asymptotic limit
Go deeper · precise statements, proofs & research scope
Local approximation bounds · pointwise lower bound fails
New terminology is linked to the definitions.
The Hessian describes the second-order departure of a scalar function from its local linearization. This connects a measurable notion of local complexity to a specific approximation problem.
A concrete bound is available without claiming universality: if f is C² on [a,b] and Ihf is its linear interpolant at the endpoints, h = b − a, then
Proof and a necessary limit on the lower bound
For each interior x, the interpolation remainder is f″(ξ)(x − a)(x − b)/2 for some ξ in the interval. The absolute product is at most h²/4, giving the bound. The endpoints have zero error.
For f(x) = x² on [0,h], the interpolant is hx, the Hessian is 2 everywhere, and the maximum error is h²/4. Yet the error at either node is zero. A strictly positive multiple of |f″(x)|h² therefore cannot bound the error from below at every point.
A lower bound must specify an appropriate norm, approximation class, cell geometry and nondegeneracy conditions. The original proof moves from a supremum bound to a pointwise bound; that step does not follow.
Scope & review. The supplied empirical suite reproduced 10/11 passes under its own criteria, including a failed rotation-invariance test. These are synthetic regression observations, not proof of a universal neural-network error law or a Yang–Mills mass gap. Review notes →
The Lift Unification
Dependence & probability lift
How does conditioning change the weight of an event?
Start here / a worked example
A change from 20% to 40% has a lift of two.
Count a small, explicitly invented population.
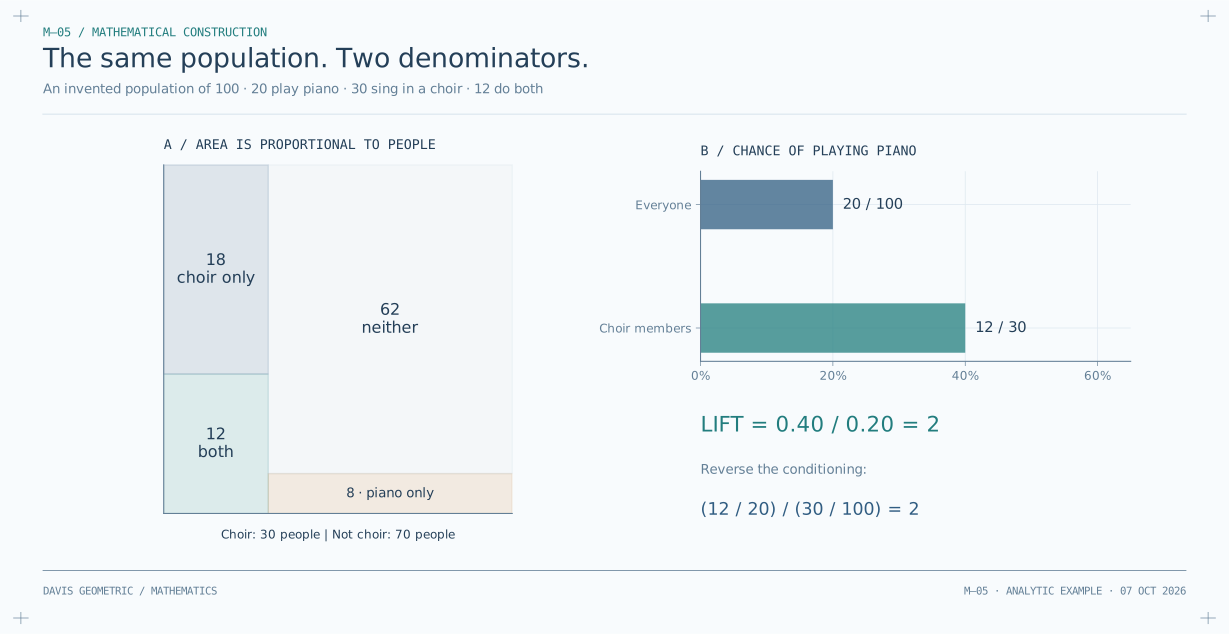
Imagine 100 people. Twenty play piano; thirty sing in a choir; twelve do both. The numbers here are a teaching example, not study data.
Change the group you are counting within.
Across everyone, the probability of playing piano is 20/100 = 20%. Among the thirty choir members, it is 12/30 = 40%. Conditioning changes the denominator because it changes the group under consideration.
Recover the symmetric formula.
Write A for playing piano and B for singing in the choir. Then the joint probability is 0.12 and the marginal probabilities are 0.20 and 0.30. Their ratio is 0.12/(0.20 × 0.30) = 2. Reversing the question gives 12/20 = 60% compared with the 30% choir baseline: again a factor of two.
This is an exact probability identity. It records association; it does not establish causation or supply a geometric curvature model.
Words for this step Event / marginal probability · Conditional probability, P(A|B) · Lift, Λ · Independence
Go deeper · precise statements, proofs & research scope
Exact identities within standard probability
New terminology is linked to the definitions.
Lift isolates a multiplicative departure from independence. For events A and B with positive marginal probabilities, define
Then P(A|B) = Λ(A,B)P(A), P(B|A) = Λ(A,B)P(B), and Λ(A,B) = Λ(B,A). Lift equals one exactly when these two events are independent. The work uses these identities to examine why conditioning and base rates can defeat informal intuition.
Proof and the distinction from a Bayes factor
Divide P(A ∩ B) by P(B) and substitute the definition of Λ. Interchanging A and B proves symmetry and the second identity. Setting Λ = 1 recovers the event-independence equation.
A binary Bayes factor compares P(B|A) with P(B|not A). Lift compares P(B|A) with the marginal P(B). They are different ratios. The algebra does not require a geometric interpretation.
Scope & review. The conditioning identities are retained and checked with exact rational arithmetic. Dependence is not itself a Riemannian curvature tensor; Bayes’ rule and the law of total probability remain valid. The geometric interpretation requires a separately specified model. Review notes →
From the positive counting system to connected set-partitions
Counting with connectivity
What changes when a count retains the relations between its elements?
Start here / a worked example
Three objects can have different ways to stay together.
Connect three labeled dots in a chain.
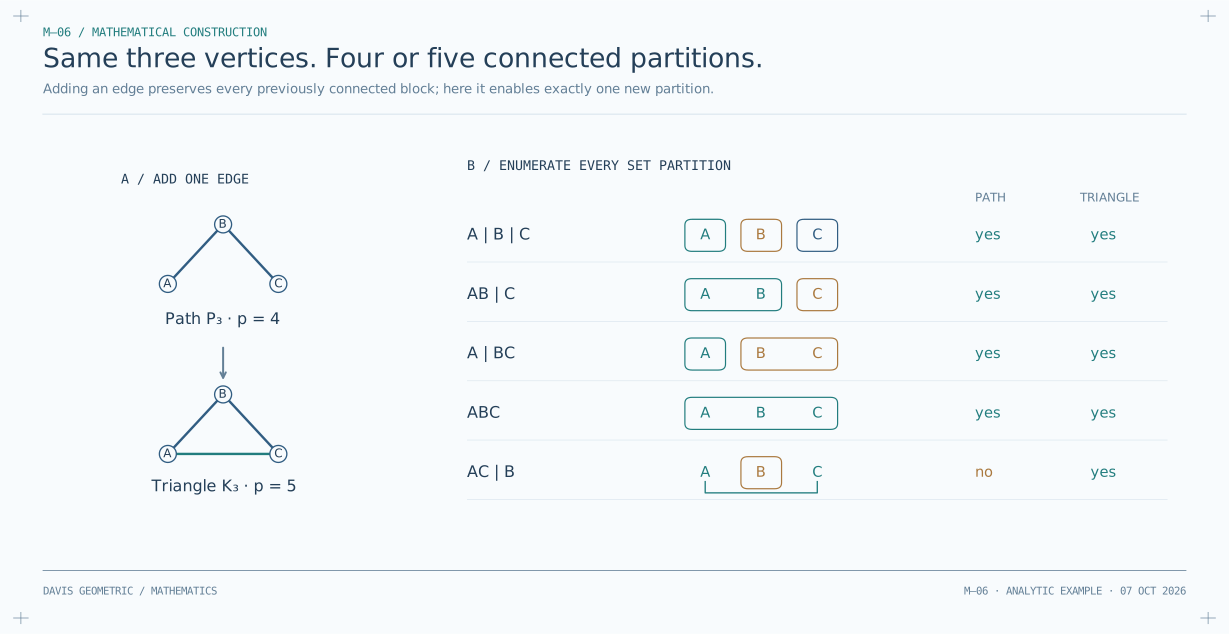
Draw A—B—C. Divide the vertices into groups, requiring every group to stay connected using edges inside that group. The four allowed divisions are shown in the plate.
Add the missing edge.
Join A directly to C to make a triangle. The old four divisions still work, and one new division becomes possible: AC | B. The number of vertices remains three, but the connected-partition count rises from four to five.
Turn the example into a proof.
Adding an edge cannot disconnect any group that was already connected. Every old connected partition therefore remains valid. The count can stay the same or increase, but cannot decrease.
This is the precise meaning of the monotonicity statement below. The counting system keeps the relationships as well as the positive count; it does not require ordinary arithmetic to abandon zero.
Words for this step Graph / spanning subgraph · Connected partition · Injection / monotonicity · Bell number
Go deeper · precise statements, proofs & research scope
Combinatorial proofs · exhaustive finite checks
New terminology is linked to the definitions.
Every genuinely new edge strictly increases the count. Put its two endpoints together and every other vertex in its own block: that grouping becomes valid only when the new edge exists. Every earlier valid grouping remains valid.
The counting program represents a positive count together with a graph. Its concrete combinatorial object is p(G): the number of vertex partitions whose blocks each induce a connected subgraph. Keeping the graph distinguishes structures with the same number of elements.
The spanning-subgraph condition is essential. The familiar special cases are p(Tn) = 2n−1 for a tree, p(Cn) = 2n − n for n ≥ 3, and p(Kn) = Bn, the Bell number.
Counting proofs
Monotonicity. Every block connected in G remains connected in H. The identity map injects the connected partitions of G into those of H.
Trees. Cutting any subset of the n − 1 edges gives a unique connected partition, and every connected partition arises this way.
Cycles. Choosing at least two cut edges gives a unique partition into cyclic intervals. There are 2ⁿ − 1 − n such subsets; adding the single-block partition gives 2ⁿ − n.
Complete graphs. Every nonempty vertex subset is connected, so every set partition is allowed.
This is the connected-set-partition object studied by Simon, Tittmann & Trinks (2011). The research program’s framing and applications should be distinguished from established combinatorial identities.
Scope & review. An independent enumerator agreed with the supplied counter on all 1,099 labeled graphs with 1–5 vertices, and checked 5,325 edge additions. Excluding the empty object defines the proposed system’s domain; it does not invalidate zero in ordinary arithmetic. Review notes →
Definitions / keep this nearby
A vocabulary you can build as you go.
Start with the worked examples. Follow any underlined term here when you need it; the browser’s Back button returns to your place. The formal notes use some additional language, included below so the next step is always available.
Representations and distances
- Representation
- A way to encode something so that we can calculate with it: for example, an angle, a pair of coordinates, or a graph.
- Equivalence
- A rule for which descriptions count as the same object. Opposite arrows are equivalent when we care only about the unoriented line they lie on.
- Manifold
- A space that looks like ordinary coordinates when you zoom in sufficiently. A circle locally looks like a line; the surface of a sphere locally looks like a plane.
- Metric
- A rule for measuring distance. In a Riemannian metric, a smoothly varying inner product first measures the lengths and angles of tangent vectors; path lengths then give distances.
- Riemannian manifold
- A smooth manifold supplied with that local rule for lengths and angles. The choice of metric is part of the model, not something supplied by the data automatically.
- Chart / smooth chartability
- A chart assigns ordinary coordinates to a local part of a space. Smooth chartability requires such descriptions to fit together with smoothly differentiable coordinate changes.
- Category / realization
- A category organizes objects and the maps between them, with rules for composing maps. A realization is a particular mathematical construction that represents the proposed structure.
- Distortion
- How much a representation changes the distances or relationships we intended to retain. A useful claim must say which distances are compared and over what region.
- Detector / threshold
- A decision rule, such as sounding an alarm when a score exceeds a chosen threshold. Nearly equal scores can produce different decisions near that threshold.
- Error budget
- A stated allowance or bound for different sources of error. Combining budgets into a probability requires assumptions about how the errors depend on one another.
- Cantelli bound
- A one-sided probability bound based on a population mean and variance. It limits how much probability can lie a specified distance above or below the mean. Estimating those moments from a sample adds another problem.
Circles, covers and measurements
- Quotient
- A new space made by treating specified points as equivalent. For an unoriented axis, a direction and the opposite direction become one point in the quotient.
- Double cover
- A map for which each point downstairs has two preimages upstairs, with the same two-sheet structure locally. The arrow-to-axis example is a double cover.
- Observable
- A specified quantity we measure or compute from a state. If two descriptions represent the same state, an observable on that state space must give the same value for both.
- Chord
- The straight segment joining two points on a circle. Its length differs from the length of the arc along the circle.
- S¹, ℝP¹ and eⁱᵅ
- S¹ means the unit circle. ℝP¹ is the space of unoriented lines through the origin in a plane. The complex-number notation eⁱᵅ is a compact way to write the circle point (cos α, sin α).
- Spin-j state
- In the formal extension, a quantum state in a specified angular-momentum representation. A highest-weight state has the largest allowed angular-momentum component along the chosen axis. This is beyond the prerequisites of the introductory example.
- Hamiltonian / spectral gap
- A Hamiltonian is an operator describing a system’s energy. Its eigenvalues are the allowed energies in the model; a spectral gap is a specified difference between them.
Transport and geometry
- Parallel transport
- A rule for carrying a vector along a path without turning it within the local geometry. On a sphere, the vector remains tangent while the tangent plane itself changes.
- Connection
- The mathematical rule that tells us how to compare nearby vectors or states. Applying this rule continuously along a path produces transport.
- Holonomy
- The transformation left after transporting around a closed loop. You return to the same base point, but the transported direction or internal state can have changed.
- Curvature / flatness
- For a connection, curvature measures the leading change produced by transport around very small loops. Flat means that this curvature vanishes. Large loops can still retain holonomy when the topology permits it.
- Simply connected / homotopy
- A path-connected space is simply connected if every loop can be continuously shrunk to a point within the space. A homotopy is such a continuous deformation; for paths we may require the endpoints to stay fixed.
- Fiber bundle / principal bundle
- A fiber bundle attaches a space of possible internal states to each base point, looking locally like a product. A principal bundle uses a symmetry group as that attached space, with a compatible group action.
- Parallel trivialization
- A consistent choice of internal reference frames across the whole base, in which the given connection transports those frames unchanged. This is stronger than merely choosing local coordinates.
- U(1), SU(2) and gauge
- U(1) is the group of rotations of a complex phase. SU(2) is a matrix symmetry group used in the advanced manuscripts. A gauge is a choice of local reference frame; changing it must not change the physical observable.
Approximation and probability
- Derivative / Hessian
- A derivative measures local rate of change. A second derivative measures how that rate changes. For several variables, the Hessian collects the second partial derivatives into a matrix.
- C²
- A function whose first and second derivatives exist and are continuous on the relevant region. This does not by itself guarantee a third-order error remainder.
- Linear interpolant
- The straight line joining two sampled values of a function. It agrees with the function at those sample points and generally differs between them.
- Supremum norm, ‖f‖∞
- The largest absolute size of f over the specified region, or the least upper bound if a maximum is not attained. A bound on maximum error is not a lower bound at every point.
- Bound / asymptotic limit
- A bound is an inequality with stated conditions. An asymptotic limit describes what happens as a parameter tends to a limit; it is not necessarily an exact formula at a finite parameter value.
- Event / marginal probability
- An event is a collection of possible outcomes, such as “this person plays piano.” Its marginal probability is its overall chance before conditioning on another event.
- Conditional probability, P(A|B)
- The chance of A among outcomes for which B holds. In a finite equally weighted population, count the people in both A and B and divide by the number in B.
- Independence
- Two events A and B are independent when P(A ∩ B) = P(A)P(B). Knowing that B occurred then does not change the probability of A, provided P(B) is positive.
- Lift, Λ
- The factor by which conditioning on one event changes the probability of the other: Λ = P(A|B)/P(A), for positive marginals. Lift 2 means twice the baseline probability.
- Bayes factor
- A ratio comparing how likely the same evidence is under two hypotheses. It compares two conditional likelihoods, rather than comparing a conditional probability with a marginal baseline.
Counting and proof language
- Graph / spanning subgraph
- A graph consists of vertices and edges joining pairs of vertices. Here graphs are undirected and simple. A spanning subgraph keeps every vertex and removes zero or more edges.
- Connected partition
- A division of all vertices into nonempty, nonoverlapping groups, where each group is connected using only vertices and edges inside that group. No vertex is omitted.
- Tree, cycle and complete graph
- A tree is connected and contains no cycle. A cycle graph is a single closed ring. A complete graph has an edge between every pair of distinct vertices.
- Bell number
- Bₙ counts all ways to partition n labeled objects into nonempty groups. For three objects there are five such partitions.
- Injection / monotonicity
- An injection assigns distinct outputs to distinct inputs. Monotonicity here means that adding edges cannot decrease the connected-partition count.
- Pigeonhole principle
- If more objects are assigned to fewer labels, at least two objects receive the same label. In the hero proof, the labels name covering balls; sharing a ball then supplies a distance bound.
- ε-ball / covering number
- An ε-ball contains states within distance ε of a center. An ε-cover is a collection of such balls covering the whole space. Nₓ(ε) is the smallest number required. Two states in one ball are at most 2ε apart by the triangle inequality.
- Compactness
- For metric spaces, a property that guarantees a finite subcover from every open cover. In particular, a compact space can be covered by finitely many ε-balls at every positive scale ε.
- Lipschitz bound
- A speed limit for a map: d(H(s), H(t)) ≤ Λ|s−t|. It controls how far readings can change, but does not force them to move or make an excursion.
- Reference frame / radial frame
- A reference frame is a chosen orthonormal basis for reading transported vectors at each point. A radial frame comes from transporting one basis along radial geodesics from a base point p inside a suitable normal ball.
- SO(n) / bi-invariant metric
- SO(n) is the compact group of orientation-preserving rotations in n dimensions. A bi-invariant metric measures rotation differences consistently under left and right multiplication by a fixed rotation.
- Injectivity radius / small-ball condition
- The injectivity radius at p limits the radius on which normal coordinates give a unique radial geodesic to each point. The additional condition √κ r₀ ≤ c, for sufficiently small c, controls the geometric estimates when sectional curvature satisfies |K| ≤ κ.
The inspectable record / 7 October 2026
Read the statements. Inspect the checks.
The focused review includes algebraic checks, exact enumeration, numerical examples and counterexamples to broader formulations. It is not a formal verification of every manuscript. The review notes document the proposed corrections and remaining proof obligations.