Representations, metrics, and the coordinate seam
Research settingNASAFoundational origins
The foundational program connects two ways of describing the same phenomenon: transformations that preserve identity, and geometry that measures meaningful change. The question is which relationships survive when one description is translated into another.
From the research record
Inspect the work
Original figures, recorded values, and explicit model details. Each exhibit identifies its source and what the comparison means.
A correction the mathematical review retains
Scroll horizontally to inspect the full table →
| Check / quantity | Recorded result | Interpretation |
|---|---|---|
| Supplied suite | 10 / 11 checks passed | Only the suite’s own finite tests |
| Test 9, original coordinates | Mean error 0.2952 | Synthetic regression |
| Test 9, rotated coordinates | Mean error 0.1425 | Same rotation-invariance check |
| Rotated / original error | 0.483 | The check failed; coordinate sensitivity remains |
The suite does not prove the proposed lower bound or a mass gap. Keeping the failed rotation check visible is part of the mathematical record.
Read the technical figure
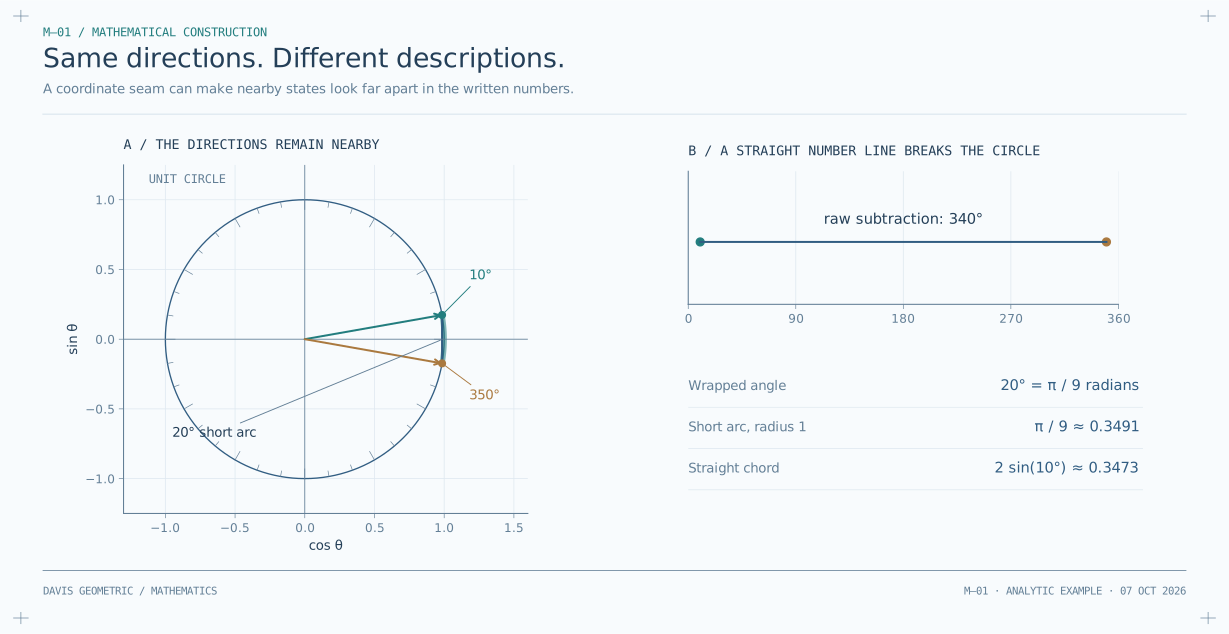
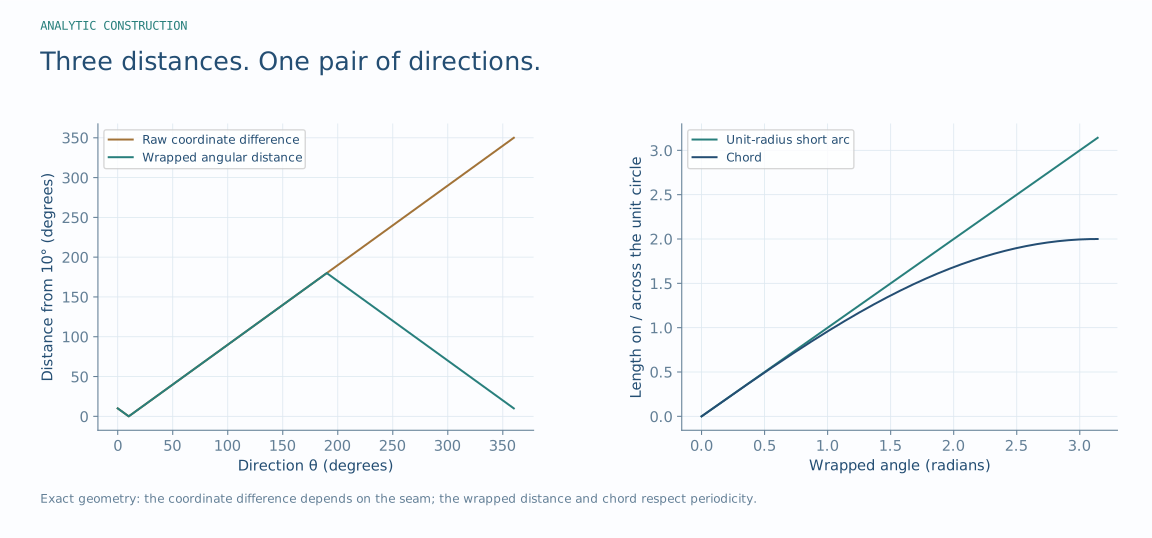
Exact mathematical construction with coordinate and metric distinctions. The companion adds the relationship to the source manuscripts.
Exact mathematical construction with coordinate and metric distinctions. The companion adds the relationship to the source manuscripts.
Supporting detail
The engineering origin of the mathematical question
A translator can preserve an identifier while losing a distinction that matters to a decision. Conversely, two numerically different records can represent the same state after a unit conversion or a change of coordinates. The Davis Manifold and Geometry of Sameness work tries to make these equivalence choices explicit.
The aim is to connect implemented translations with distances and error budgets. Such a connection requires a stated domain, metric, equivalence relation, and distortion control. It is not supplied merely by calling a data representation a manifold.
A simple quotient exposes the proof obligation
A directed arrow returns to its starting direction after 2π; an unoriented axis returns after π. The projection from arrows to axes identifies opposite directions. A quantity defined on the arrow space descends to the axis space only if it gives the same value to the directions being identified.
The current Math page develops this distinction alongside curvature and path dependence, approximation, probability lift, and connected counting. The geometric pigeonhole argument is another precisely scoped result: a finite metric cover forces a near-repeat among enough separated samples; an excursion-and-return needs an extra hypothesis.
The corrections belong to the research
The review records failed or incomplete steps in broader distortion, quotient-observable, energy, and pointwise approximation claims. The supplied approximation suite passed 10 of its 11 checks, with a rotation-invariance failure. Finite enumeration checks support particular graph statements rather than validating every manuscript.
The wider catalog retains proposed arguments about major mathematical problems as part of the research history. Inclusion does not certify their resolution. The precise statements and counterexamples in the review are the appropriate starting point for evaluating the current program.
Sources, scope, and next question
Source manuscripts, six teaching chapters, and an explicit mathematical review with corrections.
A useful next manuscript should isolate one translation-to-geometry result with its exact hypotheses and a worked implementation. That provides a reviewable contribution without asking a reader to accept every proposed cross-domain extension.
- Six mathematical walkthroughs.
- Proof review and counterexamples.
- The Davis Manifold: Geometry-First Detection with Compositional Error Budgets.
- The Geometry of Sameness: An ε-Equivalence of Translation and Distance.
- The Hodge Conjecture: A Davis Field Equations Resolution.
- Davis-Wilson Flow as Ricci Flow: An Independent Gauge-Theoretic Proof of the Poincaré Conjecture via Cache Space Collapse.
- The Smooth 4-Dimensional Poincar´e Conjecture: Whitney Embedding via Curvature Flow.
- The Crouzeix Conjecture: Shift Extremality and the Curvature Budget.
- Geodesic Confinement Resolves the Invariant Subspace Problem.
- The Davis Non-Decoupling Theorem: Why Every Flat Model of a Curved System Fails, and the Topological Size of the Debt.